We have compiled a list of manufacturers, distributors, product information, reference prices, and rankings for Location Estimation System.
ipros is IPROS GMS ・ IPROS One of the largest technical database sites in Japan that collects information on.

Location Estimation System - List of Manufacturers, Suppliers, Companies and Products | IPROS GMS

Location Estimation System Product List

1~2 item / All 2 items

Displayed results

Self-Localization System for AGV/AMR with VNS

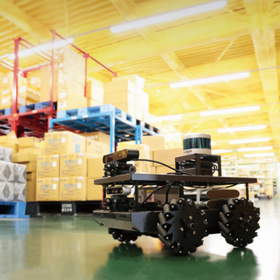
Easily implement advanced Visual SLAM with a self-positioning estimation system! Contributing to automation in factories and logistics, as well as reducing manpower for movement and inspection within warehouses.

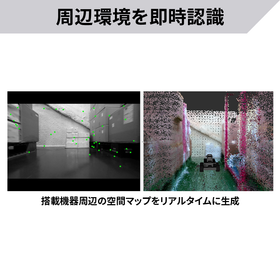
Visual SLAM is a software technology that serves as the eyes of mobile robots. By using stereo camera data captured with a wide field of view, it can simultaneously estimate three-dimensional information about the surrounding environment as well as the camera's position and orientation, allowing for flexible adaptation even in environments with frequent layout changes, such as those where cargo is regularly loaded and unloaded. 【Features】 ● Canon's software "Vision-based Navigation Software" 1. Capable of high-speed position and orientation measurement 2. Strong performance in bright, dark, and backlit conditions, with high adaptability to lighting variations and external light environments 3. Equipped with a function for map sharing between cameras 4. Includes a Canon proprietary viewer that allows for viewing position and orientation measurements ● Smart camera "SiNGRAY Stereo PRO" 1. Equipped with a high-speed AI processor and an IMU processor (9-axis gyro) 2. Simultaneously captures stereo images, color images, and 3D depth images, processing AI image recognition and self-position estimation in real-time for object recognition and gesture recognition *For more details, please download the PDF or contact us.

Added to bookmarks

Bookmarks list

Bookmark has been removed

Bookmarks list

You can't add any more bookmarks

By registering as a member, you can increase the number of bookmarks you can save and organize them with labels.

Free membership registration

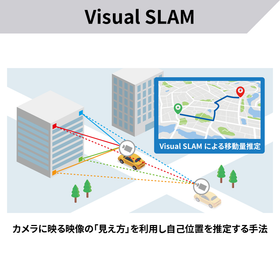
Visual SLAM for AGVs and autonomous mobile robots

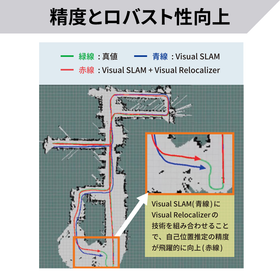
Responding to AGV position shifts and environmental changes! Achieving high-precision self-position estimation with Visual SLAM.

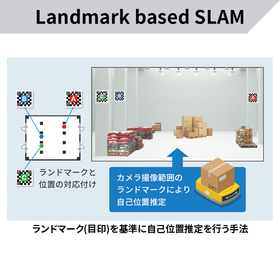
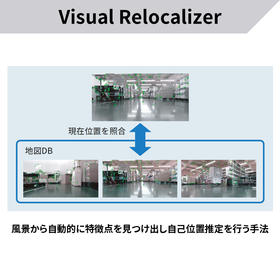
In AGVs and autonomous robots, it is necessary to accurately grasp the destination and current position to determine the travel route. This solution customizes Toshiba's unique self-position estimation technology for your system and optimizes it for real-time systems. ■ Do you have any of these challenges? - Want to improve the self-position estimation accuracy of AGVs and transport robots - Want to reduce position drift and cumulative errors that occur during long-distance travel - Want to implement SLAM that is robust to environmental changes such as ambient light, lighting, and moving obstacles - Want to combine multiple sensors such as cameras, LiDAR, and IMUs - Want to achieve autonomous driving in areas where GPS/GNSS signals are unstable - Want to generate an environmental map while simultaneously estimating self-position - Need a fast, low-memory SLAM that operates on embedded devices - Want to customize SLAM to fit your own robots or mobile units ■ Would you like to solve these challenges with SLAM? We support self-position estimation tailored to your system by combining Visual SLAM, Visual Relocalizer, landmark-based SLAM, sensor fusion, and environmental map generation.

  • スライド10.PNG
  • スライド11.PNG
  • スライド12.PNG
  • スライド6.PNG
  • スライド14.PNG
  • Software (middle, driver, security, etc.)
  • Transport and handling robots
  • Other conveying machines
  • Location Estimation System

Added to bookmarks

Bookmarks list

Bookmark has been removed

Bookmarks list

You can't add any more bookmarks

By registering as a member, you can increase the number of bookmarks you can save and organize them with labels.

Free membership registration